← Projects
micro:brawl
Two micro:bit robots play cat and mouse under a ceiling camera, driven from a web page by visitors, or by an AI. A POC built in one evening.
POC · public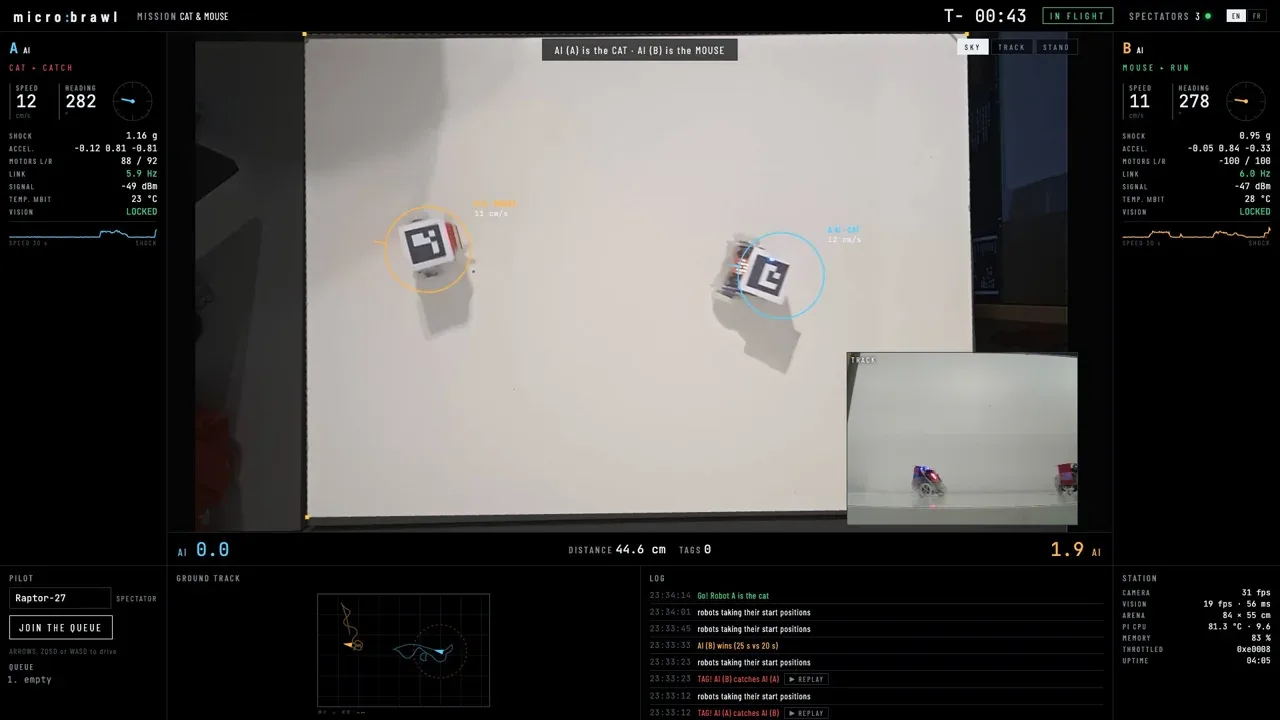
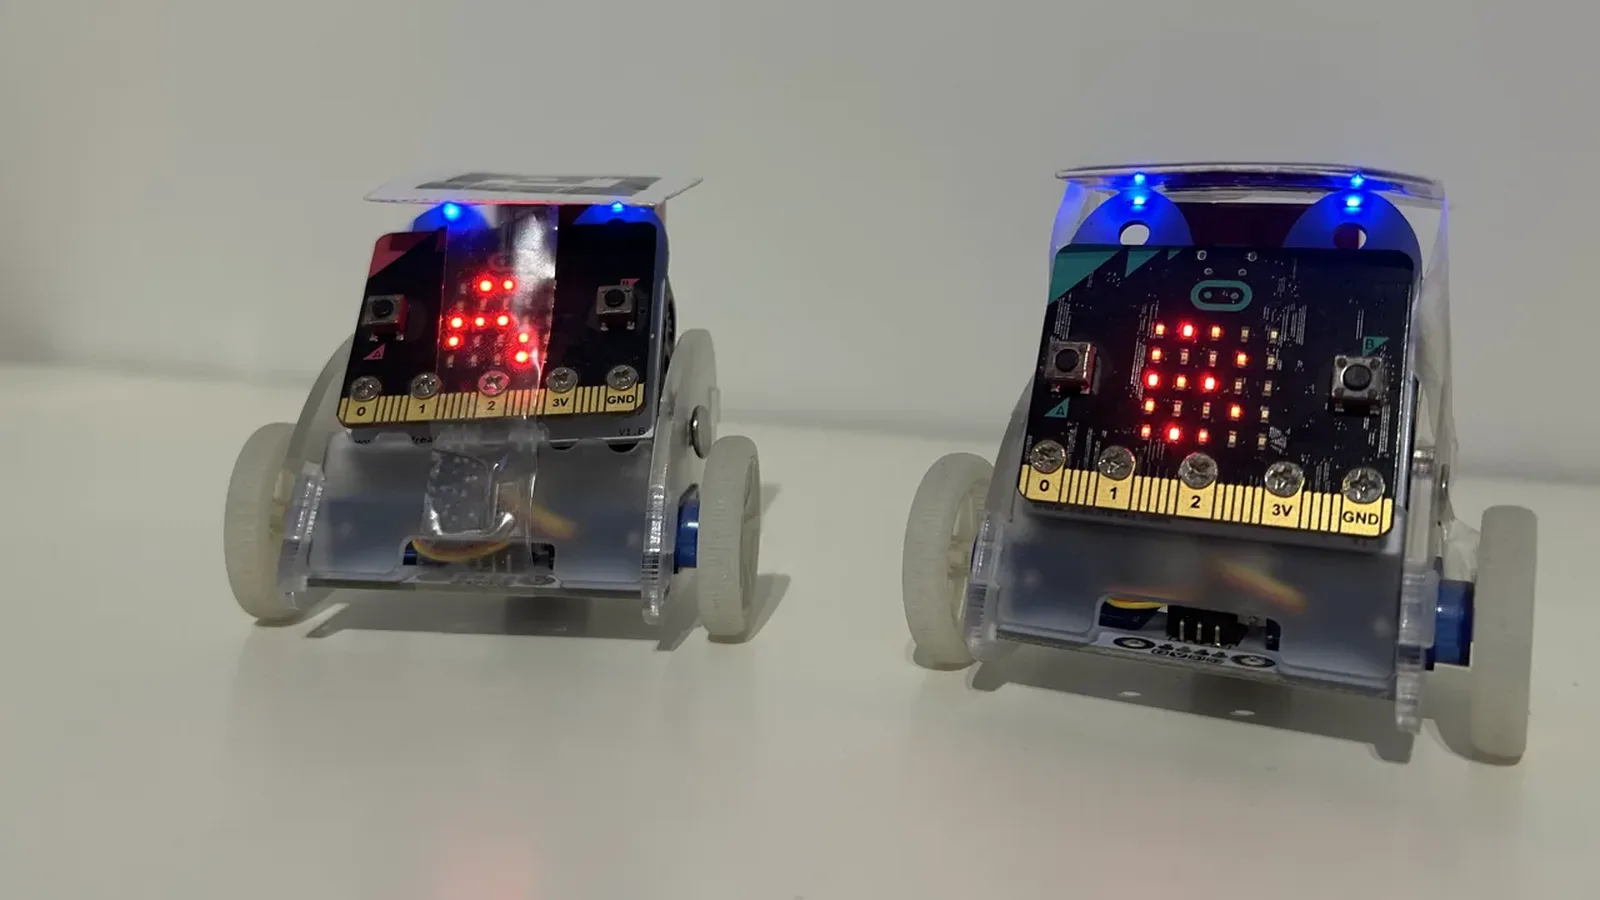
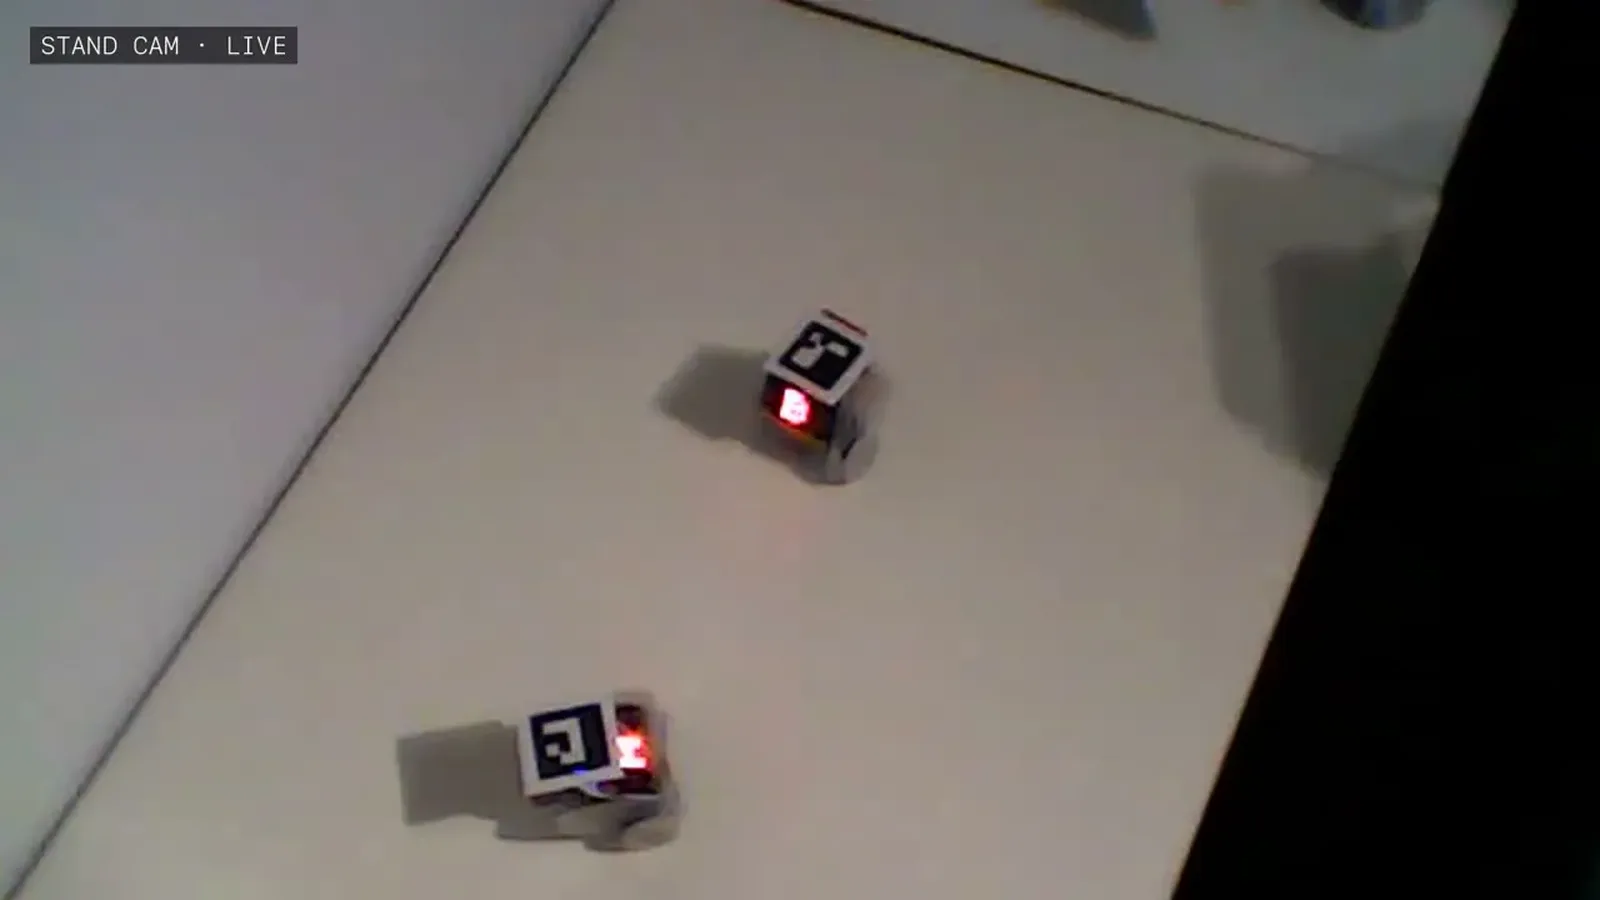
Two Kitronik :MOVE mini robots, a micro:bit V1.5 in each, a Raspberry Pi 4 that does everything, and a camera on the ceiling. Visitors queue, get a robot and drive it with the keyboard; alone, you play against the AI.
- The link: Bluetooth Low Energy, wheel speeds 20 times a second, telemetry coming back, wheels stopped if nothing arrives for 400 ms.
- The vision: 4 cm ArUco markers laid as a roof on each robot; OpenCV gives the identifier, position and heading, in centimetres after a four-click calibration.
- The game: a cat-and-mouse referee, rounds that restart from start spots, holds when a robot flips or leaves the arena, and a slow-motion replay of every tag on three cameras.
The code is public, for information: the repository.